Abstract
E-textiles, particularly knitted resistive strain sensors, have been proposed for joint motion measurements. Although combining non-elastic conductive yarns with elastic non-conductive yarns improves sensor performance, the effects of knitting patterns and strategies for integrating sensors into garments remain underexplored. This paper addresses both by: (1) comparing the characteristics of plain weft-knitted resistive strain sensors made from conductive silver-coated yarn and Lycra-based elastic yarn across multiple patterns, and (2) evaluating three integration methods–hand-sewn attachment to finished garments, snap-button attachment, and direct in-garment knitting. We find that the plated knitting pattern with conductive material on the knit side and the elastic non-conductive yarn on the purl side achieves the best sensor characteristics, with a gauge factor of 14.616 during stretching and 13.300 during release. For joint angle estimation, we compare multi-layer perceptrons and a random forest under both static holds and continuous motion for all three integration methods. Performance degradation from resistance drift can be substantially mitigated through pre-processing, including linear detrending and predicting relative rather than absolute angles. However, models trained on one integration method show limited transferability to others, underscoring the need for method-specific calibration. This work provides practical guidance on the design, fabrication, integration and data processing of knitted strain sensors for joint motion measurement.
1 Introduction
By recognizing different forms of mechanical deformation, textile sensors can monitor biological signals, such as respiratory patterns (; Molinaro et al., 2018; ), heart rates (; ; ; ) and joint motions (; ). Owing to their versatility, elasticity, and resemblance to everyday garments (), knitted resistive strain sensors are particularly well suited for joint motion measurement. Applications include detecting sleeping positions (), counting steps () as well as recognizing movement patterns which may lead to injuries ().
The characteristics of knitted strain sensors are influenced by various fabrication parameters, including the materials used, knitting pattern, and knitting structure (; ; ). Notably, demonstrated that combining conductive material such as silver-coated yarns with elastic non-conductive yarn leads to enhanced sensor performance. A knitting pattern defines how different yarns are integrated into the fabric, affecting its courses, wales, and the plated sides. The range of variations in a knitting pattern is determined by the knitting structure, which describes the stitch architecture (e.g., plain weft, rib, or interlock knitting). Although previous studies (; ; ) have investigated different knitting structures, there remains a gap in research concerning the impact of knitting patterns on sensor characteristics.
Beyond knitting patterns, the method by which sensors are integrated into garments plays a critical role in determining the overall system performance for joint motion measurement. Previous studies have employed various integration approaches, including sewing sensors onto garments (), using snap-on connectors (), and directly knitting sensors into the fabric structure (). However, no systematic comparison of these integration methods has been conducted using the same sensor type and experimental protocol. Understanding how integration methods affect sensing performance is essential for translating laboratory sensor prototypes into practical wearable systems.
To address these gaps, this study makes two primary contributions. First, we investigate the effect of knitting patterns on the characteristics of resistive strain sensors made with silver-coated conductive yarns and Lycra-based elastic yarns. While previous studies have used different knitting patterns in their research, none have constructed a controlled comparison of plain weft-knitted patterns as presented in this research. In the pre-defined fabrication conditions we ensure that other variables, such as knitting structure and structural dimension, remained constant. We compare sensor samples across 10 plain weft-knitted patterns in terms of gauge factor, working range, linear range, and hysteresis. The findings reveal that the plated pattern (P1) with the conductive yarn on the knit side and the elastic yarn on the purl side outperforms all others.
Second, we conduct a systematic evaluation of three garment integration methods using the best-performing sensor: (1) hand-sewn attachment, (2) snap-on attachment, and (3) knitted-in integration. Using a robotic arm for controlled data collection, we compare the performance of multiple machine learning models across these integration methods under both stationary (holding) and continuous motion conditions. We further validate two data pre-processing strategies, namely linear detrending and predicting relative rather than absolute angles, across all integration methods under both holding and continuous motion conditions, and assess cross-integration-method generalization capability of the trained models.
This paper extends our preliminary work presented at ISWC 2025, which focused solely on comparing the knitting patterns with a single sewn sleeve. Here we add substantial new contributions including (1) a comprehensive comparison of three garment integration methods, (2) an analysis of pre-processing effectiveness across the three garment integration methods and two machine learning methods [multi-layer perceptron (MLP) and random forest], and (3) an evaluation of cross-integration-method generalization.
2 Related work
2.1 Knitting patterns for strain sensors
The range of variations in the knitting pattern is determined by the knitting structure, which has been shown to significantly affect the characteristics of knitted strain sensors (). However, previous studies employed different knitting structures, complicating the direct comparison of knitting patterns. For instance, have integrated their sensors into elastic leggings and used plated plain weft-knitting. have demonstrated to successfully differentiate between bending angles of the wrist and fingers by using resistive knitted strain sensors in a 1x1 rib. have shown distinctions in resistance measurements from resistive knitted sensors embedded in knee and elbow sleeves with miss and tuck stitches. The importance of keeping the knitting structure consistent when comparing knitting patterns is further highlighted by seemingly contradicting findings from and , where the former employed plain weft knits and favored sensors with only one conductive course stretched in wale-direction, and the latter used rib structures and concluded that sensors with two or more wales of conductive yarns perform best. Therefore, to effectively analyze the impact of knitting patterns, it is essential to maintain consistency in knitting structure, structural dimension, and stretch direction, as implemented in this study.
2.2 Garment integration methods
Integration of sensors into garments is a critical step in developing functional wearable systems (). Several approaches have been explored in the literature. Sewing is the most common method, in which pre-fabricated sensors are attached to garments using conductive or non-conductive threads (). Although straightforward, sewn connections may introduce mechanical stress concentrations and limit the stretchability of the sensor-garment interface. Snap-on or button-based approaches use mechanical connectors to create detachable sensor-garment interfaces (), offering the advantage of easy replacement and washing but potentially introducing contact resistance variations. Knitted-in integration, where the sensor is knitted into the garment structure (; ), promises the most seamless integration but may constrain the sensor geometry and placement. Despite the variety of integration approaches, no prior study has systematically compared these methods using the same sensor type, measurement protocol, and machine learning pipeline, which is the focus of this work.
2.3 Machine learning for sensor-based motion detection
Previous studies have identified that knitted sensors may exhibit cyclic drift (), potentially caused by yarn fatigue and changes in loop structure during repeated stretching. Past research has concentrated on optimizing model architectures based on sensor types and their intended application scenarios. For instance, artificial neural networks (ANNs) have been employed to predict motion using various types of sensors (; ; ), with network architectures customized to the specific properties and application contexts of these sensors. Multi-layer perceptrons have been used for joint angle prediction (; ), while random forests () offer an alternative with built-in feature importance analysis. In this study, we use both MLP and random forest to detect joint motions from knitted strain sensors, with a focus on evaluating the effectiveness of data pre-processing across machine learning approaches and garment integration methods.
3 Methodology
To identify the optimal knitting pattern for resistive strain sensors, we fabricated ten samples–each with a distinct pattern–and evaluated them using tensile tests. The best-performing sample was then integrated into elbow sleeves using three methods to monitor elbow joint motion.
3.1 Sensor samples
Silver-coated nylon yarn produced by Shieldex with a density of 117/17 dtex has been used as the conductive material, and 1300 Baktron produced by Elasten Srl acted as the elastic non-conductive component, consisting of 90% polyamide and 10% Lycra. We produced a total of 10 samples, each representing a unique knitting pattern. All samples were knitted using a plain weft structure on a Silver Reed SK840 knitting machine, featuring a structural dimension of 15 wales and 60 courses. Additionally, 10 courses of cotton-based support yarn were included at the beginning and the end of the sample, respectively, in order to reduce the effect of manual cast-on and cast-off as well as to provide an area for attachment of the sensor to the tensile testing machine. By keeping these parameters consistent between the samples and only varying the knitting pattern, the effect of knitting pattern could be evaluated.
As depicted in Table 1, the first sample (R) consisted of only the silver-coated yarn with no elastic component, to serve as a reference for the other samples. We produced two plated samples (P1 and P2). The term "plating" refers to a knitting technique where two different yarns are used and visible separately on the two sides of the knitted fabric, depending on where the yarns are positioned in the knitting machine. We also fabricated four samples with course variations (C0, C1, C2 and C3) and three samples with wale variations (W1, W2 and W3). To measure resistance, each sample was connected to an Arduino MKR WIFI 1010 Board via a voltage divider.
Table 1
| Sample | R | P1 | P2 | C0 | C1 | C2 | C3 | W1 | W2 | W3 |
|---|---|---|---|---|---|---|---|---|---|---|
| Visualization |  | 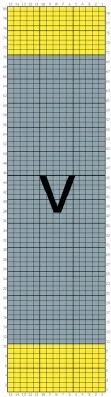 |  | 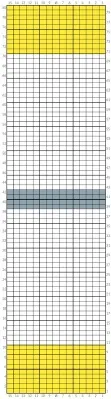 |  |  |  |  |  | 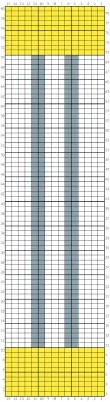 |
| Pattern | Plain silver | Plated silver (silver knits) | Plated silver (silver purls) | Silver courses (28e + 4s + 28e) | Silver courses (20e + 2s + 16e + 2s +20e) | Silver courses (18e + 4s + 16e + 4s +18e) | Silver courses (12e + 2s + 10e + 2s + 10e + 2s + 10e + 2s + 10e) | Silver wales (6e + 3s + 6e) | Silver wales (7e + 1s + 7e) | Silver wales (4e + 2s + 3e + 2s + 4e) |
| Dimensions (mm) | 65 x 44 | 62 x 44 | 67 x 24 | 45 x 16 | 46 x 16 | 51 x 14 | 48 x 15 | 43 x 20 | 41 x 14 | 41 x 19 |
Knitted sensor samples.
In the visualizations, yellow areas indicate the support yarn, gray sections the silver-coated conductive yarn and white sections the elastic non-conductive yarn. The “v” for plated samples denotes silver on the knit-stitch side and “~” silver on the purl side. In the pattern description, “e” indicates elastic courses/wales and “s” silver courses/wales. The dimensions refer to the size of the sensing area, excluding the yellow support area.
It should be explicitly noted that each sample has only been created once, and thus comparison within the same knitting pattern will not be possible during this study. Accordingly, the comparison between the knitting patterns should be regarded as descriptive, and fabrication of further samples per knitting pattern is recommended for future research.
3.2 Tensile tests
To determine the selected characteristics of the sensor samples, we performed tensile tests using a TA.XTplus texture analyser from Stable Micro Systems, as depicted in Figure 1A. The samples were stretched by 60% of their original length at rest, reaching a total of 160% of their original length, and then released back to their original length at a constant strain speed of 10 mm/s in both directions. The strain distance of 60% was not chosen based on a potential breaking point of the sensor, but on two distinct aspects: firstly, this distance is well within the elastic limit of Lycra-blend yarn (typically above 100%). Secondly, it covers the strain range required for elbow flexion at the chosen joint geometry: in-vivo measurements report skin surface strains of up to roughly 40%–50% over articulating joints (Maiti et al., 2016), and prior textile strain sensors integrated into elbow sleeves have been shown to operate at comparable strain levels during the full 0–90° flexion range (). Furthermore, breaking points were not determined since the samples were needed intact for tensile testing. Each test comprised 120 cycles; the first 20 were excluded from the subsequent data analysis to account for the initial fiber rearrangement after fabrication. Resistance was recorded at 200 Hz.
Figure 1
From the average of the remaining 100 cycles, the working range (WR) was computed. Accordingly, the average strain cycle has been divided into overlapping sliding windows of 20 data points with a step size of 1. In each sliding window, the average of the 20 data points has been computed with the average of the consecutive sliding window. As the WR, we have determined the largest range in which the difference between these sliding windows was consecutively larger than 0.0001. Sliding windows have been chosen to reduce the effect of small-scale variability in the resistance values. Within the WR, the linear range (LR) was determined as the largest strain range in which the error between a linear fit and the data (R2) did not exceed 0.96. The gauge factor (GF) was computed as the slope of this linear fit, while the hysteresis (H) was calculated as the largest strain difference between the stretch and release directions.
The reference sample (R), the plated samples (P1 and P2) as well as the samples with wale variations (W1, W2 and W3) have been further examined in speed and hold tests, in order to observe how their sensing behavior differed during various movement speeds and strain distances. The selection criteria is detailed in Section 4.1.1. In the speed test, samples were stretched by 60% of their original length and subsequently released at five different speeds (2, 5, 10, 20 and 40 mm/s) for a total of 10 repetitions each, which were averaged during data analysis. These strain rates have been selected to include typical bend-cycle durations of 0.5–5 s reported for human elbow flexion during activities of daily living (; ). The hold tests consisted of stretching the sample from its original length at rest by six selected strain distances (10, 20, 30, 40, 50 and 60% of the original length) at a speed of 10 mm/s. With some margin toward the lower and upper end of the range, typical strain distances during a bend-cycle (20%–40% strain) are included in this selection. The respective distance was held for 60 s, before releasing the sample back to its original length.
Evaluation of the cyclic stability has been executed for the reference sample (R), the plated sample with the conductive material on the knit-stitch side and the elastic yarn on the purl-stitch side (P1) as well as the sample with one conductive wale between seven elastic wales on each side (W2). The selection criteria is detailed in Section 4.1.1. To that end, the samples were stretched by 40% of their original length at a speed of 10 mm/s for 1,050 cycles, where the first 50 were excluded from data analysis. For each sample, the cyclic stability test was performed twice, with a timespan of 1 week between the test repetitions.
Based on these three evaluation criteria, a three-step selection process of knitting patterns has been created. A knitting pattern was selected to be included in the next study part based on the following criteria: during the sensor characterization in the first step, the samples in a group of knitting pattern (plated, wales or courses) with the smallest linear ranges and lowest gauge factors have been excluded from further testing. Based on the stability of the resistance values measured during the second step (speed and hold testing), the two best-performing samples were selected to be evaluated in the last round of testing. In this step (cyclic stability testing), the sample with the smallest drift in resistance values was determined. As the last remaining sample, it was re-evaluated for its performance in all previous tests, to consider any possibilities of other samples performing better in the previous tests. The reference sample was automatically included in all three testing rounds as a baseline.
3.3 Garment integration methods
Based on the sensor characterization results (Section 4.1), the pattern P1 was identified as the best-performing one and used for comparing the three methods of embedding the sensor into an elbow sleeve, as shown in Figure 2.
Figure 2
3.3.1 Hand-sewn attachment (sewn)
The sensor was hand-sewn onto an elastic sleeve along its edges using non-conductive thread, with the knit stitches facing outward and the purl stitches against the sleeve fabric. This method ensures a secure attachment while preserving the sensor's full sensing area. The sleeve provides adequate flexibility to accommodate the elastic strain of the knitted sensor while ensuring a tight fit around the elbow joint.
3.3.2 Snap-on buttons (buttons)
Snap-on buttons were attached at strategic points along the sensor edges, allowing the sensor to be mechanically fastened to the corresponding buttons on the sleeve. This approach enables easy sensor replacement and removal for repair or washing. However, the discrete attachment points can introduce localized stress concentrations and potentially alter the strain distribution across the sensor.
3.3.3 Knitted-in integration (knitted)
The sensor was directly knitted into the sleeve, creating a seamless sensor-garment interface. This method eliminates the need for post-fabrication attachment steps and provides the most uniform strain transfer between the garment and the sensor. However, it fixes sensor placement during fabrication and limits modularity.
3.4 Joint angle estimation
To evaluate the feasibility of knitted resistive strain sensors for joint angle estimation across different integration methods, we used the elbow joint angle as a case study.
3.4.1 Data collection
Each of the three sleeves (sewn, buttons, and knitted) was placed on a TinkerKit Braccio robotic arm, as shown in Figure 1B, and resistance measurements were recorded at approximately 200 Hz across various angular positions in both stationary and continuous motion modes. The robotic arm was programmed to move to ten distinct positions covering the full range of motion (0°, 10°, 20°, 30°, 40°, 50°, 60°, 70°, 80°and 90°). These angles have been determined by the resolution of the TinkerKit Braccio servo and are dense enough to expose hysteresis and drift artifacts at small angles.
Two motion conditions were tested for each sleeve: (1) a holding condition, in which the elbow was held for 5 s at each target angular position; (2) a continuous condition, involving uninterrupted movement between angles. For each condition, all possible combinations of starting and target positions were used. Accordingly, each of the 10 angles was used as a starting position and combined with each of the 10 angles as a target position, leading to a total of 100 start-target combinations. These combinations were repeated 10 times in random order, resulting in a total of 1,000 trials per sleeve per condition. This yielded approximately 850,000 data points for each holding dataset and 106,000 data points for each continuous dataset, for a total of six datasets (one per sleeve per condition).
3.4.2 Data pre-processing
The raw resistance signals were segmented into sliding windows of 50 samples with a step of 25 samples. Each window was labeled with the average angle (discretized to 10° increments) and the pre-dominant motion state (bending, releasing, or holding). Motion-state labels were assigned as follows: “bending” if the window contained at least 10 bending samples, “releasing” if it contained at least 10 releasing samples, and “holding” otherwise. A second-order Butterworth low-pass filter with a cutoff frequency of 20 Hz was applied to each window to reduce high-frequency noise. The filtered data were normalized using the mean and standard deviation of the training set.
To mitigate resistance drift during cyclic strain, two pre-processing strategies were implemented and evaluated across all three integration methods under both holding and continuous conditions:
Linear detrending: a linear regression model was fitted to the full resistance time series, and the estimated linear trend was subtracted from each window. This approach is motivated by the observation that resistance drift accumulates approximately linearly over repeated trials, especially under the holding condition. Removing this global linear trend yields drift-corrected resistance values that more accurately track the ground-truth joint angle.
Relative angle prediction: instead of predicting the absolute angular position of each window, the model predicts the angle change between consecutive windows (Δθ = θt−θt−1). This approach exploits the assumption that relative resistance changes within short time intervals are more consistent than absolute values under drift conditions. Because drift evolves slowly relative to the window step (~0.15 s), consecutive angle differences are largely independent of the absolute baseline level.
3.4.3 Machine learning models
We defined two classification tasks: three-class motion state detection (bending, releasing, or holding), and a 10-class angle classification with labels 0°–90° in 10° increments. The choice for the classification approach is based on multiple factors. Firstly, the robot arm does not provide information on the current angle of the elbow joint. Hence, no continuous baseline data for the angle of the elbow joint was available, only the 10 distinct angle classes. Secondly, due to the sensor drift identified during the cyclic stability testing, the resistance values for a given angle are not constant, but changing depending on the previous motion pattern of the joint. Accordingly, a regression problem would not take these aspects into account. We compared two machine learning approaches: MLP and random forest. Although powerful, deep learning architectures (e.g., LSTM, 1D-CNN, or Transformers) were excluded from this study because overfitting would be a possibility given the limited amount of training data.
3.4.4 Multi-layer perceptron (MLP)
Following prior works (; ), we used an MLP with three hidden layers, each containing 128 neurons with ReLU activation. The models were trained using Adam optimizer with a learning rate of 0.0001 and early stopping with a validation fraction of 10%. Separate models were trained for angle prediction and motion state prediction.
3.4.5 Random forest (RF)
As a complementary approach, we employed random forests () with 200 trees and a maximum depth of 20. Random forests offer several advantages for this application: they are robust to overfitting, provide feature importance rankings, and do not require extensive hyperparameter tuning. The same classification tasks (motion state and prediction) were performed.
To ensure a fair across-sleeve comparison, we apply the same hyperparameter search grid (Table 2) independently to every (sleeve, pipeline) combination, and select the configuration that minimizes the angle-prediction RMSE on a held-out validation set. For each (sleeve, pipeline), the windowed data are split chronologically into three contiguous segments: the first 70% are used to fit each candidate hyperparameter configuration (with the inner MLP additionally using a random 10% of this segment for early stopping), the next 10% serve as a held-out validation set on which the best configuration is selected, and the final 20% are reserved as the test set (identical to the test set used in the previous, single-configuration version of this analysis). After hyperparameter selection, the best configuration is re-fitted on the first 80% of the data and evaluated once on the 20% test set. The selected best hyperparameters per cell are reported in Table 3. The grid in Table 2 was derived from values commonly used in prior wearable-sensor literature (e.g., ), for the MLP architecture range, and the robust-default ranges in similar studies for random forests). Table 4 shows the 6 selected pipelines and the processing step in which it has been applied.
Table 2
| Model | Hyperparameter | Candidates |
|---|---|---|
| MLP | hidden_layer_sizes | (64), (128, 128), (128, 128, 128), (256, 128, 64) |
| learning_rate_init | 10−4, 10−3 | |
| alpha (L2) | 10−5, 10−4, 10−3 | |
| RF | n_estimators | 100, 200, 500 |
| max_depth | 10, 20, None | |
| min_samples_leaf | 1, 2, 4 |
Hyperparameter search grid applied independently to every (sleeve, pipeline) combination.
The full grid was searched exhaustively on the held-out validation set; remaining hyperparameters were fixed (MLP: activation=ReLU, solver=Adam, max_iter=5000, batch_size=auto, early_stopping=True, validation_fraction=0.1, n_iter_no_change=20; RF: max_features=sqrt).
Table 3
| Sleeve | Pipeline | Best hyperparameters |
|---|---|---|
| Sewn (H) | Raw MLP | (128, 128, 128), lr = 10−3, α = 10−4 |
| Filtered MLP | (128, 128, 128), lr = 10−3, α = 10−5 | |
| Feature MLP | (256, 128, 64), lr = 10−3, α = 10−4 | |
| Filtered RF | n = 200, depth = None, leaf = 2 | |
| Detrended MLP | (256, 128, 64), lr = 10−3, α = 10−4 | |
| Relative angle MLP | (256, 128, 64), lr = 10−3, α = 10−5 | |
| Buttons (H) | Raw MLP | (128, 128, 128), lr = 10−3, α = 10−4 |
| Filtered MLP | (128, 128, 128), lr = 10−3, α = 10−5 | |
| Feature MLP | (256, 128, 64), lr = 10−3, α = 10−4 | |
| Filtered RF | n = 500, depth=None, leaf=1 | |
| Detrended MLP | (256, 128, 64), lr = 10−3, α = 10−4 | |
| Relative angle MLP | (128, 128, 128), lr = 10−4, α = 10−4 | |
| Knitted (H) | Raw MLP | (256, 128, 64), lr = 10−3, α = 10−4 |
| Filtered MLP | (128, 128, 128), lr = 10−3, α = 10−5 | |
| Feature MLP | (128, 128, 128), lr = 10−3, α = 10−3 | |
| Filtered RF | n = 100, depth = None, leaf = 1 | |
| Detrended MLP | (256, 128, 64), lr = 10−3, α = 10−3 | |
| Relative angle MLP | (256, 128, 64), lr = 10−4, α = 10−4 | |
| Sewn (C) | Raw MLP | (128, 128, 128), lr = 10−3, α = 10−5 |
| Filtered MLP | (128, 128, 128), lr = 10−3, α = 10−4 | |
| Feature MLP | (128, 128, 128), lr = 10−4, α = 10−4 | |
| Filtered RF | n = 200, depth = 20, leaf = 2 | |
| Detrended MLP | (256, 128, 64), lr = 10−3, α = 10−5 | |
| Relative angle MLP | (256, 128, 64), lr = 10−3, α = 10−4 | |
| Buttons (C) | Raw MLP | (128, 128), lr = 10−3, α = 10−3 |
| Filtered MLP | (256, 128, 64), lr = 10−3, α = 10−5 | |
| Feature MLP | (128, 128), lr = 10−4, α = 10−4 | |
| Filtered RF | n = 200, depth = None, leaf = 1 | |
| Detrended MLP | (128, 128), lr = 10−3, α = 10−4 | |
| Relative angle MLP | (128, 128, 128), lr = 10−3, α = 10−5 | |
| Knitted (C) | Raw MLP | (128, 128, 128), lr = 10−3, α = 10−4 |
| Filtered MLP | (256, 128, 64), lr = 10−3, α = 10−4 | |
| Feature MLP | (128, 128), lr = 10−4, α = 10−5 | |
| Filtered RF | n = 200, depth = 10, leaf = 2 | |
| Detrended MLP | (256, 128, 64), lr = 10−3, α = 10−3 | |
| Relative angle MLP | (128, 128), lr = 10−3, α = 10−5 |
Best hyperparameter configurations selected on the validation set, per (sleeve, pipeline).
MLP entries report hidden_layer_sizes, learning rate, and L2 regularization strength; Random Forest entries report number of trees, maximum depth, and minimum samples per leaf.
Table 4
| Pipeline filter | Low-pass features | Statistical | Linear detrend | Relative angle | Model |
|---|---|---|---|---|---|
| Raw MLP | MLP | ||||
| Filtered MLP | ✓ | MLP | |||
| Feature MLP | ✓ | ✓ | MLP | ||
| Filtered RF | ✓ | RF | |||
| Detrended MLP | ✓ | ✓ | MLP | ||
| Relative Angle MLP | ✓ | ✓ | MLP |
Overview of the six evaluation pipelines.
✓ indicates that the corresponding component is applied.
4 Results
4.1 Sensor characterization
4.1.1 Tensile test
As shown in Figure 3, all samples except C3 exhibited an increase in resistance with rising strain at first, followed by a plateau and a decrease. This mirrors prior observations (), attributed to an initial decrease in contact points due to elongation, followed by an increase in contacts from lateral compression as the fabric narrows. The magnitude of these changes, however, varies across samples, reflecting the influence of the different knitting patterns.
Figure 3
As listed in Table 5, the largest linear ranges in both stretch and release were observed for the wale-variation samples (W1, W2 and W3) and the plated samples (P1 and P2). Notably, P1 exhibited an exceptionally large gauge factor 14.616 during stretching and 13.300 during release. Although the lowest hysteresis values were obtained for the course-variation samples (C0 and C2), their linear and working ranges as well as gauge factors were inadequate for reliable motion tracking. Accordingly, the course-variation samples (C0, C1, C2, and C3) were excluded from further testing.
Table 5
| Stretch | Release | ||||||
|---|---|---|---|---|---|---|---|
| Sample | WR (s) | LR (s) | GF (s) | WR (r) | LR (r) | GF (r) | H |
| R | 0.0%–11.8% | 0.0%–11.8% | 1.852 | 0.0%–14.4% | 1.1%–14.4% | 1.781 | 0.095 |
| P1 | 0.0%–40.3% | 5.3%–40.3% | 14.616 | 0.0%–47.7% | 0.9%–47.7% | 13.300 | 0.051 |
| P2 | 9.0%–25.4% | 9.0%–25.4% | 4.940 | 0.0%–31.8% | 0.0%–31.8% | 3.289 | 0.054 |
| C0 | 0.0%–4.3% | — | — | 2.7%–12.0% | — | — | 0.037 |
| C1 | 11.2%–18.9% | — | — | 9.0%–13.1% | — | — | 0.072 |
| C2 | 0.0%–12.8% | 0.0–12.8% | 0.362 | 0.0%–17.0% | 0%–17.0% | 0.500 | 0.046 |
| C3 | 16.09%–25.4% | — | — | 45.4%–59.3% | 45.4%–59.3% | 0.300 | 0.087 |
| W1 | 9.7%–23.0% | 13.3%–20.7% | 2.507 | 13.1%–32.0% | 13.1%–32.0% | 1.715 | 0.087 |
| W2 | 0.0%–19.3% | 10.2%–17.5% | 3.158 | 22.0%–34.6% | 28.2%–33.0% | 4.623 | 0.066 |
| W3 | 23.2%–42.8% | 23.2%–42.8% | 3.279 | 27.5%–48.1% | 27.5%–48.1% | 4.300 | 0.051 |
| RP | 1.8%–18.1% | 1.8%–18.1% | 2.315 | 0.0%–21.8% | 0.0%–21.8% | 2.881 | 0.105 |
Comparison of sensor characteristics, in terms of working range (WR), linear range (LR), gauge factor (GF) and hysteresis (H) in the stretch and release directions of the strain cycle.
“–” indicates that values could not be computed according to the criteria outlined in Section 3.2.
Regarding statistical analysis, we considered the selected knitting pattern as an independent variable and the achieved WR, LR and GF in both directions as dependent variables. Given that the Shapiro–Wilk tests indicated the data were not normally distributed and Levene's tests showed unequal variance across the groups, we employed the Kruskal–Wallis test for a non-parametric assessment using single trial data. The Kruskal–Wallis tests revealed statistically significant differences across WR, LR and GF in both directions among the samples (p < 0.05 for all conditions). Subsequent pairwise comparisons using Dunn's tests confirmed that P1 was significantly different from the other samples across all metrics. For example, the GF of P1 in the stretch direction was significantly different from that of R with p = 1.025 × 10−37, and from that of W2 with p = 3.933 × 10⁻¹⁵.
4.1.2 Speed and hold testing
As shown in Figure 4A, the overall resistance-strain profile is consistent across speeds for a given sample. However, peak resistance increases with speed across all samples, with the smallest change observed for P1 and the largest for W3. This may be caused by reduced time at higher speeds for the silver-coated fibers to rearrange and re-establish contact patterns similar to those at lower speeds.
Figure 4
All samples showed resistance peaks at the beginning and at the end of the holding period, as illustrated in Figure 4B. These peaks likely reflect the strain level, as the resistance values between them generally vary less across strains. P1 exhibited the smallest difference in peak resistance between the slowest and fastest speeds, indicating that its resistance-strain profile is less sensitive to movement speed than the other samples. W2 appeared more stable during the speed and hold tests than the other samples. Accordingly, R, P1, and W2 were selected for cyclic stability testing.
4.1.3 Cyclic stability
In Figure 5, all samples exhibit a continuous increase in resistance during cyclic testing. The change between the first and 1,000th strain cycles is smallest for R and largest for W2. The duration of the strain cycle is dependent on the physical size of the sensor based on the respective knitting pattern. Accordingly, stretching to 140% of the original size leads to different distances for the sensor samples, and with a constant speed of 10mm/s, this leads to varying strain durations. After a 1-week rest, baseline resistance is generally higher across all samples, and P1 shows a smaller increase in resistance compared with W2. Combined with its superior performance in the tensile test and acceptable stability in the speed and hold test, P1 is therefore identified as the best-performing design and is used to evaluate garment integration methods.
Figure 5
4.2 Effect of elastic material
To assess the impact of elastic yarn on sensor performance, we fabricated a variant (RP) identical to P1 except that the elastic yarn was replaced with a non-conductive, non-elastic yarn. RP was subjected to the same tensile test protocol as the other samples. As shown in Figure 6 and the bottom row of Table 5, RP exhibited a larger working range, linear range and gauge factor than R, but smaller than P1, which uses an elastic yarn. These results indicate that P1's superior sensing performance can be attributed to the use of elastic yarn, aligning with prior studies (; ; ) that combined elastic materials with conductive yarns.
Figure 6
Our study also took one step further and explored different knitting patterns for integrating the yarns. Our findings suggest that the conductive yarn should be located on the knit-stitch side of the plated fabric rather than the purl-stitch side. This is highly likely due to the ability of the conductive yarn to spread out more freely when it is positioned on the knit side with the v-shaped appearance of the stitches. While the elastic yarn compresses the fabric on the purl side, it does not constrain the conductive yarn. As a result, more contact points form when the sensor is relaxed and the range of contact point separation under stretch is larger, improving sensing performance
4.3 Comparison of signal quality across integration methods
Table 6 summarizes the key signal properties for each integration method under both holding and continuous conditions. The metrics are defined as follows: Baseline is the mean resistance at rest (0° flexion), reflecting the intrinsic resistance of the sensor and its connections; Range is the full span between minimum and maximum observed resistance, indicating the sensor's dynamic response to strain; Noise is the median rolling standard deviation (50-sample window), quantifying short-term signal fluctuations unrelated to joint motion; and Drift is the slope of a linear fit to the resistance time series over all trials, capturing the systematic change in baseline resistance over time due to mechanical fatigue or viscoelastic relaxation.
Table 6
| Sewn | Buttons | Knitted | ||||
|---|---|---|---|---|---|---|
| Metric | H | C | H | C | H | C |
| Baseline (Ω) | 8.65 | 12.86 | 29.73 | 28.69 | 8.98 | 11.75 |
| [8.57, 8.73] | [12.37, 13.35] | [28.14, 31.35] | [27.49, 29.87] | [8.90, 9.07] | [11.38, 12.12] | |
| Range (Ω) | 15.17 | 19.82 | 86.62 | 80.92 | 20.27 | 17.80 |
| [12.93, 15.17] | [18.10, 19.82] | [76.54, 86.62] | [73.98, 80.92] | [18.97, 20.27] | [14.93, 17.80] | |
| Noise (Ω) | 0.170 | 1.327 | 0.287 | 2.966 | 0.252 | 0.768 |
| [0.169, 0.171] | [1.320, 1.334] | [0.283, 0.289] | [2.947, 2.996] | [0.250, 0.253] | [0.763, 0.773] | |
| Drift (× 10−5) | 0.11 | 5.08 | 1.33 | 17.37 | 0.17 | 6.44 |
| [0.11, 0.11] | [5.01, 5.15] | [1.32, 1.33] | [17.25, 17.49] | [0.17, 0.17] | [6.40, 6.48] | |
Signal quality comparison across three integration methods under holding (H) and continuous (C) conditions.
Values shown include baseline resistance (mean over per-trial means at 0°), overall resistance range, noise level (median rolling standard deviation), and drift slope (resistance change per sample index). Square brackets contain 95% confidence intervals (bootstrap with 10,000 resamples for baseline and noise; trial-level block bootstrap with 1,000 resamples for range; analytical OLS standard error for the drift slope).
As shown in Table 6, the sewn sleeve exhibited the lowest baseline resistance (8.65 Ω under holding) and noise level (0.170 Ω under holding), indicating stable electrical contact. The button-attached sleeve showed substantially higher baseline resistance (29.73 Ω), likely due to additional contact resistance at the snap-on connection points, and a dramatically larger resistance range (86.62 Ω), suggesting highly non-linear strain-resistance behavior. The knitted sleeve demonstrated intermediate baseline resistance (8.98 Ω) comparable to the sewn sleeve, but with slightly higher noise.
Notably, all three integration methods exhibited positive resistance drift over time. The drift was smallest for the sewn sleeve (1.1 × 10⁻⁶ per sample under holding) and largest for the button sleeve (1.3 × 10⁻⁵), an order of magnitude higher. Under continuous conditions, drift increased substantially for all methods, with the button sleeve reaching 17.4 × 10⁻⁵. These differences in drift magnitude have direct implications for the effectiveness of detrending strategies, as discussed in Section 4.4.2.
To assess the reliability of the signal-quality metrics reported in Table 6 and the statistical significance of the differences between integration methods, we computed 95% confidence intervals (bootstrap for baseline/range/noise; analytical OLS standard error for the drift slope) and pairwise Mann–Whitney U-tests on the per-trial (baseline, range, drift) and per-window (noise) distributions. All three integration methods differ significantly from each other on baseline resistance, resistance range, and noise level under both holding and continuous conditions (Mann–Whitney U, p < 10−3 for every pairwise comparison; statistical power ≥0.93 for all). Drift slopes also differ significantly between all pairs under the holding condition (p < 0.05, power ≥0.94). Under continuous motion, drift differs significantly between Sewn-vs-Knitted (p = 1.9 × 10⁻⁴, power 1.00) and marginally between Sewn-vs-Buttons (p = 0.023, power 0.25); the Buttons-vs-Knitted drift comparison is not significant (p = 0.35, power 0.36, i.e., the test is underpowered to detect small differences). These results confirm that the signal-quality differences summarized in Table 6 are not attributable to within-sleeve sampling variability, while the two underpowered drift comparisons should be interpreted as “insufficient evidence” rather than “no difference”.
The noise figure in Table 6 is the median of a 50-sample rolling standard deviation taken over the entire time series, which therefore averages over both rest and motion segments. To verify that this aggregate value is representative of the sensor at rest, we additionally computed a rest-only noise estimate restricted to the post-peak hold portion of each trial (samples after the resistance reaches its smoothed peak, i.e. when the robot has stopped moving). Under the holding condition the rest-only median noise differs from the value in Table 6 by only 6%–18% and yields the same ordering across sleeves (sewn < knitted < buttons: 0.160, 0.230 and 0.235 Ω respectively), so the conclusions drawn from Table 6 are unchanged. The signal-to-noise ratio (SNR), defined as the overall resistance range divided by the rest-only noise, is 95, 368 and 88 for the sewn, button and knitted sleeves under the holding condition; the button sleeve's high SNR despite its larger absolute noise reflects its much wider dynamic range. Under continuous motion each trial lasts only ~0.5 s so the rest-only estimate is based on far fewer samples; it nevertheless reveals that the button sleeve's overall noise of 2.97 Ω drops by an order of magnitude (to 0.24 Ω) when restricted to the brief stationary segments, indicating that most of the button sleeve's continuous-condition noise originates from contact transients during movement rather than from the sensor at rest.
4.4 Joint angle estimation
To systematically evaluate how each pre-processing strategy and model choice affect joint angle prediction, we compared the six pipelines defined in Section 3.4.3: raw MLP (no pre-processing), Filtered MLP (low-pass filtering only), Feature MLP (statistical features from filtered windows), Detrended MLP (filtering + linear drift removal), Relative Angle MLP (predicting angle changes between consecutive windows), and Filtered RF (random forest on filtered windows). Performance was evaluated using three metrics: accuracy, defined as the proportion of test windows correctly classified into the ground-truth 10° angle bin; weighted F1 score, computed as the weighted average of per-class F1 scores with class frequencies as weights, accounting for class imbalance; and RMSE (root mean squared error), calculated as shown in Equation 1.
where and θi denote the predicted and ground-truth angles (in degrees) for the i-th test window, and N is the total number of test windows.
4.4.1 Performance without pre-processing
Raw MLP:Table 7 presents the joint angle and motion state prediction performance of the MLP model trained on raw (unfiltered) data across all six datasets defined in Section 3.4.1. For joint angle estimation, the sewn sleeve achieved the highest accuracy under both holding (34.6%, RMSE = 10.47°) and continuous conditions (45.1%, RMSE = 13.46°). Under holding, the sewn sleeve substantially outperformed the button sleeve (20.3%, RMSE = 38.35°) and the knitted sleeve (19.8%, RMSE = 27.65°). Under continuous motion, the sewn sleeve remained the most accurate, while the button (20.0%, RMSE = 26.28°) and knitted (24.6%, RMSE = 26.31°) sleeves achieved comparable mid-range errors. For motion state prediction, all integration methods achieved high accuracy under holding (91.4%–97.8%), indicating that distinguishing between bending, releasing, and holding is feasible regardless of integration method. However, state prediction accuracy dropped considerably under continuous motion, particularly for the button sleeve (54.5%), reflecting the higher noise and non-linear resistance behavior of the snap-on attachment. The pairwise sleeve-vs-sleeve differences in Raw-MLP angle prediction error are highly significant for five of the six comparisons (Mann–Whitney U on per-window absolute errors, p < 10−30), with large effect sizes against the sewn sleeve (Cohen's d = −1.12 for sewn-vs-buttons and d = −0.98 for sewn-vs-knitted under holding; d = −0.72 and d = −0.64 respectively under continuous motion) and a moderate but still significant difference between buttons and knitted under holding (d = 0.35, p < 10−40). Under continuous motion, the buttons-vs-knitted difference is no longer significant (d = 0.04, p = 0.07, statistical power 0.14), indicating that the per-window error distributions of these two sleeves overlap heavily once continuous-motion noise is taken into account. These tests confirm that the accuracy gaps between the sewn sleeve and the other two methods are not attributable to sampling variability in the held-out test set.
Table 7
| Angle prediction | State prediction | ||||
|---|---|---|---|---|---|
| Sleeve | Acc (%) | F1 | RMSE (°) | Acc (%) | F1 |
| Sewn (H) | 34.6 | 0.341 | 10.47 | 97.8 | 0.978 |
| Buttons (H) | 20.3 | 0.142 | 38.35 | 91.4 | 0.893 |
| Knitted (H) | 19.8 | 0.187 | 27.65 | 96.0 | 0.959 |
| Sewn (C) | 45.1 | 0.452 | 13.46 | 78.7 | 0.788 |
| Buttons (C) | 20.0 | 0.191 | 26.28 | 54.5 | 0.529 |
| Knitted (C) | 24.6 | 0.217 | 26.31 | 73.5 | 0.738 |
MLP performance on raw data across integration methods under holding and continuous conditions, respectively.
Filtered MLP: as listed in Table 8, applying a Butterworth low-pass filter produced small, mostly neutral changes in RMSE across cells after per-sleeve hyperparameter tuning. Under holding the sewn sleeve was essentially unchanged (10.47° to 10.40°), the button sleeve modestly improved (38.35° to 37.04°), and the knitted sleeve slightly degraded (27.65° to 28.42°). Under continuous motion, the changes were marginal (sewn 13.46° to 13.53°; buttons 26.28° to 26.27°; knitted 26.31° to 29.34°). Pairwise Mann–Whitney U-tests on per-window absolute errors within each sleeve reveal that, after per-sleeve hyperparameter tuning, low-pass filtering is statistically indistinguishable from Raw MLP under most conditions. The exceptions are small but significant effects in two cells: for the button sleeve under holding the filtered model is slightly better than raw (d = 0.045, p = 2.4 × 10⁻²), while for the knitted sleeve under holding the raw model is marginally better (d = −0.039, p = 3.3 × 10⁻²). In all other (sleeve, condition) pairs the Raw-vs.-Filtered difference is not significant (p>0.27). The reversal of the previous finding (that filtering was substantially detrimental for the button sleeve) is consistent with HP tuning compensating for the spectral content of the snap-on transients via a wider MLP and stronger regularization rather than via the cut-off filter.
Table 8
| Method | Sewn | Buttons | Knitted |
|---|---|---|---|
| Holding Condition (n≈6, 800 test windows per sleeve) | |||
| Raw MLP | 10.47 (10.2–10.7) | 38.35 (37.7–39.0)‡ | 27.65 (27.2–28.1)⋆ |
| Filtered MLP | 10.40 (10.2–10.6) | 37.04 (36.4–37.7) | 28.42 (28.0–28.9) |
| Feature MLP | 11.27 (11.0–11.5)‡ | 39.49 (38.9–40.1)‡ | 27.40 (27.0–27.8) |
| Filtered RF | 10.25 (10.0–10.5)⋆ | 34.86 (34.3–35.4)⋆ | 27.67 (27.2–28.1) |
| Detrended MLP | 7.07 (6.9–7.3)⋆ | 32.44 (32.0–32.9)⋆ | 18.51 (18.1–18.9)⋆ |
| Relative angle MLP† | 2.40 | 3.97 | 3.81 |
| Continuous Condition (n≈840 test windows per sleeve) | |||
| Raw MLP | 13.46 (12.4–14.5) | 26.28 (24.7–27.8) | 26.31 (24.7–27.9) |
| Filtered MLP | 13.53 (12.3–14.7) | 26.27 (24.8–27.7) | 29.34 (27.6–31.0) |
| Feature MLP | 14.91 (14.2–15.6)‡ | 25.43 (24.2–26.6) | 26.95 (26.0–27.9)‡ |
| Filtered RF | 12.49 (11.6–13.4) | 28.44 (27.0–29.9) | 26.28 (24.9–27.7)⋆ |
| Detrended MLP | 13.77 (12.8–14.7) | 31.56 (29.8–33.3)‡ | 15.94 (14.4–17.5)⋆ |
| Relative Angle MLP† | 6.63 | 15.10 | 8.04 |
Comprehensive comparison of angle prediction RMSE (°) across models, pre-processing methods, and integration methods.
95% bootstrap confidence intervals (10,000 resamples) are shown in parentheses where available. Lower RMSE indicates better performance. All values are for the test set (20% held-out split). †Relative Angle MLP predicts angle changes between consecutive windows; its RMSE measures change prediction accuracy rather than absolute angle accuracy. Within each sleeve, ⋆ indicates the pipeline is significantly better and ‡ significantly worse than Filtered MLP (Mann–Whitney U on per-window absolute errors, p < 0.05).
Feature MLP: replacing the full filtered window with four hand-crafted statistical features (mean, standard deviation, minimum, and maximum) produced mixed effects that depend on both the sleeve and the motion condition. Under holding, feature extraction significantly degraded the sewn (10.40° to 11.27°, p < 10−3) and button (37.04° to 39.49°, p < 10−4) sleeves, while leaving the knitted sleeve essentially unchanged (28.42° to 27.40°, p = 0.12, non-significant). Under continuous motion, features still significantly degraded the sewn sleeve (13.53° to 14.91°, p < 10−14) but significantly improved the knitted sleeve (29.34° to 26.95°, p < 10−13), with no significant change for the button sleeve (26.27° to 25.43°, p = 0.18). This suggests that the value of compact statistical summaries depends jointly on the noise level and the underlying signal structure: under noisier continuous motion they can suppress fine-grained noise where it dominates, whereas under holding the longer per-angle dwell makes the full waveform more informative, so feature compression discards useful temporal dynamics.
Filtered RF: according to Table 8, random forest (RF) achieved performance competitive with MLP in most cells. Under holding, RF was significantly better than Filtered MLP on the sewn (10.25° vs. 10.40°, p = 0.02) and button sleeves (34.86° vs. 37.04°, p = 2 × 10⁻³). Under continuous motion, RF outperformed Filtered MLP on the sewn (12.49° vs. 13.53°) and knitted (26.28° vs. 29.34°, p = 0.02) sleeves, while performing slightly worse on the button sleeve (28.44° vs. 26.27°). The consistent RF advantage under continuous motion suggests that the ensemble-based decision boundaries of RF are more robust to the higher variability present in noisier signals.
4.4.2 Effectiveness of pre-processing for drift compensation
To mitigate resistance drift, we evaluated two complementary strategies: linear detrending and relative angle prediction, applied under both holding and continuous conditions.
Detrended MLP:Table 9 summarizes the effect of linear detrending on joint angle prediction under both holding and continuous conditions. Under the holding condition, the improvement was statistically significant for all three sleeves (Mann–Whitney U-test, p < 10−2). The most notable improvement is for the sewn sleeve, with RMSE dropping from 10.40° to 7.07° (−3.33°). For the knitted sleeve, a substantial improvement was observed (RMSE from 28.42° to 18.51°, −9.91°). The button sleeve also showed performance improvement (from 37.04° to 32.44°, −4.60°), although its absolute error remains high due to non-linear resistance drift caused by variable contact resistance at the snap-on points.
Table 9
| Sleeve | Without detrending | With detrending | ΔRMSE |
|---|---|---|---|
| Holding condition | |||
| Sewn | 10.40 | 7.07 | −3.33 |
| Buttons | 37.04 | 32.44 | −4.60 |
| Knitted | 28.42 | 18.51 | −9.91 |
| Continuous condition | |||
| Sewn | 13.53 | 13.77 | +0.23 |
| Buttons | 26.27 | 31.56 | +5.29 |
| Knitted | 29.34 | 15.94 | −13.39 |
Effect of linear detrending on angle prediction RMSE (°) under holding (H) and continuous (C) conditions.
Lower RMSE indicates better performance.
Under the continuous condition, the results were more nuanced. The knitted sleeve showed a dramatic improvement (RMSE from 29.34° to 15.94°, −13.39°), suggesting its drift remained approximately linear under continuous motion. In contrast, the button sleeve showed performance degradation (RMSE from 26.27° to 31.56°, +5.29°) that was statistically significant (d = −0.17, p = 0.03), and the sewn sleeve was essentially unchanged (RMSE from 13.53° to 13.77°). These findings indicate that the effectiveness of linear detrending depends on both the integration method and the measurement condition: detrending is beneficial when the underlying drift is approximately linear over the recording (as in the knitted sleeve under both conditions, and the holding condition more generally), but fails when the drift is non-stationary at the recording-level time scale, as happens for the button sleeve under continuous motion where the drift slope is over an order of magnitude larger than under holding (1.7 × 10⁻⁴ vs. 1.3 × 10⁻⁵).
Relative angle MLP: instead of predicting the absolute angle of each window, we trained the model to predict the angle change between consecutive windows. Because drift evolves slowly relative to the window step (~0.15 s), consecutive changes are largely independent of the baseline, making this approach inherently robust to both stationary and non-stationary drift.
As shown in Table 8, the Relative Angle MLP achieved consistently low RMSE for predicting angular changes across all conditions. In this case, the RMSE measures the error between consecutive windows, and is therefore not directly comparable to the absolute-angle RMSE of other pipelines. Under the holding condition, the RMSE ranged from 2.40° (sewn) to 3.97° (buttons), indicating accurate prediction of small inter-window angle variations. Under the continuous condition, RMSE was higher (6.63° for sewn, 15.10° for buttons, 8.04° for knitted), reflecting larger and more frequent angle changes. Notably, the relative approach showed smaller performance differences across integration methods compared to absolute prediction pipelines, suggesting greater robustness to signal quality variations between sleeves. Accurate prediction of angle changes has practical value for tracking angular velocity and detecting motion events in real-time applications.
Taking the sewn sleeve as example, the confusion matrices in Figure 7 illustrate the angle prediction patterns before and after drift compensation. Under the holding condition (left column), linear detrending removes the characteristic upward shift caused by the gradually increasing resistance baseline, bringing predictions closer to the diagonal. Under the continuous condition (right column), relative-angle prediction similarly improves accuracy, though some confusion between adjacent angle classes remains in both cases.
Figure 7
4.5 Cross-integration-method generalization
Can a model trained on data from one sleeve be applied to another sleeve that uses a different integration method (e.g., from a sewn sleeve to a knitted one)? Table 10 summarizes the results of cross-sleeve generalization experiments. Diagonal entries (training and testing on the same integration method) consistently yield lower errors than off-diagonal entries (cross-method transfer). Under the holding condition, the sewn-to-sewn RMSE was 10.40°, whereas training on sewn and testing on buttons increased RMSE to 44.73°, indicating near-random predictions over the 0°–90° range. Transfer is also asymmetric: the knitted-to-sewn RMSE is 30.80° versus 25.40° for sewn-to-knitted, possibly due to the similar baseline resistance range of sewn and knitted. Under continuous conditions, the same overall pattern holds, with cross-method RMSE typically 2–3 × higher than same-method RMSE. Considering the limited transferability, when users switch integration methods the ML model should be recalibrated.
Table 10
| Train \Test | Sewn | Buttons | Knitted |
|---|---|---|---|
| Holding Condition | |||
| Sewn | 10.40 | 44.73⋆ | 25.40⋆ |
| Buttons | 27.77 | 37.04 | 31.30 |
| Knitted | 30.80⋆ | 42.84⋆ | 28.42 |
| Continuous Condition | |||
| Sewn | 13.53 | 34.35⋆ | 28.05⋆ |
| Buttons | 33.90⋆ | 26.27 | 31.80⋆ |
| Knitted | 26.48⋆ | 38.80⋆ | 29.34 |
Cross-integration-method generalization RMSE (°) for angle prediction under holding (top) and continuous (bottom) conditions.
Rows indicate the integration method of the training sleeve, columns indicate that of the test sleeve. ⋆ indicates the off-diagonal cell's per-window absolute-error distribution is significantly larger than the same-row diagonal cell, as depicted by the bold values (one-sided Mann–Whitney U, p < 0.05).
For the integration method comparison, we computed Cohen's d effect sizes on per-window absolute errors using the Filtered MLP pipeline. The performance gap between the sewn and both other methods was large (Cohen's d = −1.09 for sewn-vs.-buttons and d = −1.02 for sewn-vs-knitted under holding; d = −0.77 and −0.72 respectively under continuous motion, all with p < 10−37), confirming that the sewn sleeve's superiority is not attributable to sampling variability within the test set. The difference between button and knitted sleeves was moderate under holding (d = 0.26, p < 10−21) but negligible and not significant under continuous motion (d = −0.04, p = 0.24, statistical power 0.15).
To quantify how much worse each cross-method transfer is compared to the corresponding same-method baseline, we ran one-sided Mann–Whitney U-tests on per-window absolute errors (off-diagonal > diagonal). After Bonferroni correction across 12 off-diagonal cells (six per condition), 11 of the 12 cells are significantly worse than their diagonal (p < 0.05/12). The single exception is the holding-condition cell where a model trained on the button sleeve is applied to the sewn sleeve: this transfer is not significantly worse than the within-button baseline (p = 0.95, d = −0.24), simply because the within-button baseline is already very poor (37.04°, near the worst observed in Table 10). Under continuous motion, every off-diagonal cell is significantly worse than its diagonal at the rank level, but the effect sizes vary substantially (Cohen's d from 0.00 to +1.09); in particular the knitted-to-sewn continuous transfer, while statistically significant in the rank-based test, has a near-zero mean-error effect size (d = 0.002), reflecting that the sewn sleeve's cleaner signal can partially compensate for a model trained on a noisier integration method. These observations underscore that poor same-method performance, rather than a fundamental inability to transfer, can sometimes dominate the cross-method comparison, an important nuance when drawing conclusions about domain adaptation for textile sensors.
5 Discussion
5.1 Garment integration methods
When interpreting the results of the integration method comparison, it should be considered that only one sample was fabricated for each integration method. Accordingly, it cannot be estimated how large the variability of different physical samples of the same integration method would be, and the conclusions drawn from the variability between the samples of different integration methods should be interpreted as descriptive rather than inferential. Creation of multiple samples per integration method is highly recommended for future studies.
Each of the three integration methods has its advantages and disadvantages. Hand-sewn attachment (Sewn) achieved the best overall machine learning performance across all conditions. For angle prediction, the sewn sleeve achieved the lowest RMSE with Detrended MLP under holding (RMSE = 7.07°) and was best with Filtered RF under continuous motion (RMSE = 12.49°), substantially outperforming the other two integration methods. Its uniform edge attachment ensures consistent strain transfer and low noise (0.170 Ω), yielding the cleanest signal.
Snap-on attachment (Buttons) showed the lowest ML performance, with angle prediction RMSE in the 32–39° range under holding and 26–32° under continuous motion, depending on the pipeline. The discrete attachment points introduced substantially higher baseline resistance (29.73 Ω vs. 8.65 Ω for sewn), greater noise (0.287 Ω), and the largest drift (1.3 × 10⁻⁵ per sample). The wide resistance range (86.62 Ω, several times larger than for the other two sleeves) suggests highly non-linear strain-resistance behavior at the connection points. That said, the button approach offers a practical benefit: easy sensor replacement.
Knitted-in integration performed between the other two methods, with angle prediction RMSE dropping from 28.42° (Filtered MLP) to 18.51° (Detrended MLP) under holding, and from 29.34° to 15.94° under continuous motion. Its signal characteristics were similar to the sewn sleeve (baseline 8.98 Ω, range 20.27 Ω). This method provides the most seamless sensor-garment interface and suits automated manufacturing, but it makes updating or repositioning the sensor difficult.
The cross-integration-method generalization results expose a practical challenge that has been largely overlooked in the literature. While most prior studies (; ) focused on within-system performance, our finding that transfer accuracy across integration methods approaches random chance (10% for 10 classes) emphasizes the need for standardized integration approaches and calibration protocols in wearable sensing systems. This also motivates future research into domain adaptation techniques () tailored to textile sensor data.
5.2 Implications for data pre-processing
Our results demonstrate that the two drift compensation strategies, namely linear detrending and relative angle prediction, exhibit complementary strengths depending on the integration method and measurement condition.
Linear detrending proved highly effective under the holding condition for all three integration methods, with the most dramatic improvement for the knitted sleeve (−9.91°). Under the continuous condition, however, its effectiveness was integration-method-dependent: the knitted sleeve again showed a dramatic improvement (−13.39°), the sewn sleeve was essentially unchanged (+0.23°), and the button sleeve was significantly degraded (+5.29°). This divergence reflects their drift characteristics: the knitted sleeve's drift remains approximately linear even under continuous motion, whereas the button sleeve's drift slope grows by more than an order of magnitude between holding and continuous conditions, causing a global linear model to misfit the recording.
Relative angle prediction, which reformulates the task as estimating angular changes between consecutive windows, showed consistently low RMSE across all conditions and integration methods. By operating on inter-window differences rather than absolute values, this approach is inherently robust to both stationary and non-stationary drift.
Future work should explore non-linear drift models (e.g., polynomial or exponential) for mechanically connected sensors such as the button sleeve, as well as combining detrending with relative angle estimation for optimal performance.
5.3 Statistical power and the limits of inferential claims
We computed post-hoc statistical power (two-sided test, α = 0.05) for every Mann–Whitney U comparison reported in Tables 6–10, using the observed Cohen's d and per-window sample sizes (the t-test power formulation upper-bounds the Mann–Whitney power via the 0.955 asymptotic relative efficiency between the two tests). Across 102 pairwise tests, the median power is 1.00 and 62 (61%) reach a power ≥0.99, reflecting the large per-window sample sizes (thousands of windows per sleeve under holding, hundreds under continuous motion). However, 33 of the 102 tests (32%) fall below the conventional 0.80 threshold. The low-power tests are almost exclusively comparisons with small observed effect sizes (|d| < 0.1), such as Filtered MLP versus Raw MLP within the sewn or knitted sleeves under either condition (power 0.06–0.53), and the buttons-vs-knitted contrast under continuous motion (d = 0.04, power 0.14). For these tests our data cannot distinguish “no effect” from “a small effect we are underpowered to detect”.
This pattern carries two important implications. First, the very high power of most comparisons should not be over-interpreted: the effective replication unit in this study is the integration method, of which we have only one physical sample each (Section 5.1). High per-window power tells us that the observed differences are not within-sample sampling noise; it does not tell us that the same differences would persist across different physical sleeves built using the same integration method. Second, the negative significance results we report (e.g., the loss of significance for the buttons-vs-knitted contrast under continuous motion, or the equivalence of Raw and Filtered MLP within the sewn sleeve) should be reported as “insufficient evidence for a difference at the per-window level” rather than “no difference”, given the limited power. Future studies with multiple physical sleeves per integration method are needed to support stronger inferential claims about integration-method-level differences.
6 Conclusions and future work
This study systematically compared knitting patterns and garment integration methods for resistive strain sensors. The plated pattern P1 achieved the best sensing characteristics. Among integration methods, hand-sewn attachment yielded the highest angle prediction accuracy. Linear detrending and relative angle prediction effectively mitigated resistance drift, though their effectiveness varied by integration method and motion condition. Cross-method generalization remained limited, highlighting the need for method-specific calibration.
Regarding future work, we will focus on the following perspectives: firstly, each integration method was evaluated with a single sleeve. Fabricating and testing multiple sleeves per method will enable statistical assessment of inter-sleeve variability. Secondly, we will explore multi-sensor setups to improve joint-angle estimation and extend from simpler joints (e.g., elbow) to more complex ones (e.g., shoulder, hip). Thirdly, we will apply deep learning architectures that better capture temporal dynamics, such as LSTMs () and Transformers, to improve predictions–especially under continuous motion where temporal context is critical. Fourthly, we will upgrade the robot arm to enable systematic evaluation of body shape, skin-fabric friction, perspiration, and other factors affecting sensor performance.
Statements
Data availability statement
The raw data supporting the conclusions of this article will be made available by the authors, without undue reservation.
Author contributions
AS: Writing – original draft, Visualization, Conceptualization, Methodology, Investigation, Data curation, Writing – review & editing. YZ: Writing – review & editing, Investigation, Data curation, Writing – original draft, Conceptualization. YX: Conceptualization, Writing – review & editing, Project administration, Writing – original draft, Supervision.
Funding
The author(s) declared that financial support was not received for this work and/or its publication.
Conflict of interest
The author(s) declared that this work was conducted in the absence of any commercial or financial relationships that could be construed as a potential conflict of interest.
Generative AI statement
The author(s) declared that Generative AI was not used in the creation of this manuscript.
Any alternative text (alt text) provided alongside figures in this article has been generated by Frontiers with the support of artificial intelligence and reasonable efforts have been made to ensure accuracy, including review by the authors wherever possible. If you identify any issues, please contact us.
Publisher’s note
All claims expressed in this article are solely those of the authors and do not necessarily represent those of their affiliated organizations, or those of the publisher, the editors and the reviewers. Any product that may be evaluated in this article, or claim that may be made by its manufacturer, is not guaranteed or endorsed by the publisher.
References
1
AbtahiF.JiG.LuK.RödbyK.SeoaneF. (2015). A knitted garment using intarsia technique for heart rate variability biofeedback: evaluation of initial prototype . Annu. Int. Conf. IEEE Eng. Med. Biol. Soc. 2015, 3121–3124. doi: 10.1109/EMBC.2015.7319053
2
AliyanaA. K.YangD.TangsirinaruenartO.StyliosG. K. (2024). A garment-integrated textile stitch-based strain sensor device, IoT-enabled for enhanced wearable sportswear applications. Results Eng. 23:102794. doi: 10.1016/j.rineng.2024.102794
3
AnS.TuncelY.BasaklarT.KrishnakumarG. K.BhatG.OgrasU. Y. (2021). MGait: model-based gait analysis using wearable bend and inertial sensors . ACM Trans. Internet Things3, 1–24 doi: 10.1145/3485434
4
AtalayA.SanchezV.AtalayO.VogtD. M.HaufeF.WoodR. J.et al. (2017). Batch fabrication of customizable silicone-textile composite capacitive strain sensors for human motion tracking. Adv. Mat. Technol. 2:1700136. doi: 10.1002/admt.201700136
5
AtalayO.AtalayA.HusainM.KennonW. (2017). Comparative study of the weft-knitted strain sensors. J. Industrial Textiles 46. doi: 10.1177/1528083715619948
6
AtalayO.KennonW.DemirokE. (2015). Weft-knitted strain sensor for monitoring respiratory rate and its electro-mechanical modeling. IEEE Sensors J. 15, 110–122. doi: 10.1109/JSEN.2014.2339739
7
BozaliB.GhodratS.JansenK. M. B. (2023). Development of a knitted strain sensor for health monitoring applications. Eng. Proc. 30:10. doi: 10.3390/engproc2023030010
8
BozaliB.GhodratS.PlaudeL.van DamJ. J. F.JansenK. M. B. (2022). Development of low hysteresis, linear weft-knitted strain sensors for smart textile applications. Sensors22:7688. doi: 10.3390/s22197688
9
BreimanL. (2001). Random forests. Machine Learning45:5–32. doi: 10.1023/A:1010933404324
10
CastanoL. M.FlatauA. B. (2014). Smart fabric sensors and e-textile technologies: a review. Smart Mat. Struct. 23:053001. doi: 10.1088/0964-1726/23/5/053001
11
FischerS.AbtahiB.WarnckeM.BöhmerC.WingerH.SachseC.et al. (2024). Novel weft-knitted strain sensors for motion capture. Micromachines15:222. doi: 10.3390/mi15020222
12
GatesD. H.WaltersL. S.CowleyJ.WilkenJ. M.ResnikL. (2016). Range of motion requirements for upper-limb activities of daily living. Am. J. Occup. Therapy70:7001350010. doi: 10.5014/ajot.2016.015487
13
GeißlerD.ZhouB.BelloH.SoryszJ.RayL. S. S.JavaheriH.et al. (2024). Embedding textile capacitive sensing into smart wearables as a versatile solution for human motion capturing. Sci. Rep. 14:15797. doi: 10.1038/s41598-024-66165-z
14
HanniganB. C.CuthbertT. J.AhmadizadehC.MenonC. (2024). Distributed sensing along fibers for smart clothing. Sci. Adv. 10:eadj9708. doi: 10.1126/sciadv.adj9708
15
HochreiterS.SchmidhuberJ. (1997). Long short-term memory. Neural Comput. 9:1735–1780. doi: 10.1162/neco.1997.9.8.1735
16
IsaiaC.McmasterS.McNallyD. (2020). Study of performance of knitted conductive sleeves as wearable textile strain sensors for joint motion tracking. Annu. Int. Conf. IEEE Eng. Med. Biol. Soc. 2020, 4555–4558. doi: 10.1109/EMBC44109.2020.9176429
17
JansenK. M. (2020). Performance evaluation of knitted and stitched textile strain sensors. Sensors20:7236. doi: 10.3390/s20247236
18
KimJ.-H.KooB.-H.KimS.-U.KimJ.-Y. (2024). Measurement of 3D wrist angles by combining textile stretch sensors and AI algorithm. Sensors24:1685. doi: 10.3390/s24051685
19
LiY.MiaoX.ChenJ.JiangG.LiuQ. (2021). Sensing performance of knitted strain sensor on two-dimensional and three-dimensional surfaces. Mat. Design197:109273. doi: 10.1016/j.matdes.2020.109273
20
LiY.TakahashiR.YukitaW.MatsutaniK.CaremelC.IwamotoY.et al. (2025). “Plug-n-play e-knit: prototyping large-area e-textiles using machine-knitted magnetically-repositionable sensor networks,” in: Proceedings of the Nineteenth International Conference on Tangible, Embedded, and Embodied Interaction, TEI 25. doi: 10.1145/3689050.3705973
21
LiY.ZhouY.ShenC.StewartR. (2024). “E-textile sleeve with graphene strain sensors for arm gesture classification of mid-air interactions,” in: Proceedings of the Eighteenth International Conference on Tangible, Embedded, and Embodied Interaction, TEI 24. doi: 10.1145/3623509.3633374
22
LiangX.CongH.DongZ.JiangG. (2022). Size prediction and electrical performance of knitted strain sensors. Polymers14:2354. doi: 10.3390/polym14122354
23
LiuM.Lake-ThompsonG.WescottA.BeebyS.TudorJ.YangK. (2024). Design and development of a stretchable electronic textile and its application in a knee sleeve targeting wearable pain management. Sensors and Actuators A: Physical369:115102. doi: 10.1016/j.sna.2024.115102
24
LuoN.ZhangJ.DingX.ZhouZ.ZhangQ.ZhangY.-T.et al. (2018). Textile-enabled highly reproducible flexible pressure sensors for cardiovascular monitoring. Adv. Mat. Technol. 3:1700222. doi: 10.1002/admt.201700222
25
MaitiR.GerhardtL.-C.LeeZ. S.ByersR. A.WoodsD.Sanz-HerreraJ. A.et al. (2016). In vivo measurement of skin surface strain and sub-surface layer deformation induced by natural tissue stretching. J. Mech. Behav. Biomed. Mat. 62:556–569. doi: 10.1016/j.jmbbm.2016.05.035
26
MolinaroN.MassaroniC.PrestiD.SaccomandiP.TomasoG.ZolloL.et al. (2018). Wearable textile based on silver plated knitted sensor for respiratory rate monitoring. Annu. Int. Conf. IEEE Eng. Med. Biol. Soc. 2018, 2865–2868. doi: 10.1109/EMBC.2018.8512958
27
PanS. J.YangQ. (2010). A survey on transfer learning. IEEE Transac. Knowled. Data Eng. 22:1345–1359. doi: 10.1109/TKDE.2009.191
28
SiS.SunC.QiuJ.LiuJ.YangJ. (2022). Knitting integral conformal all-textile strain sensor with commercial apparel characteristics for smart textiles. Appl. Mat. Today27:101508. doi: 10.1016/j.apmt.2022.101508
29
TangJ.WuY.MaS.YanT.PanZ. (2022). Flexible strain sensor based on CNT/TPU composite nanofiber yarn for smart sports bandage. Composites Part B: Eng. 232:109605. doi: 10.1016/j.compositesb.2021.109605
30
Vega-GonzalezA.GranatM. H. (2005). Continuous monitoring of upper-limb activity in a free-living environment. Arch. Phy. Med. Rehabil. 86:541–548. doi: 10.1016/j.apmr.2004.04.049
31
WangJ.SoltanianS.ServatiP.KoF.WengM. (2020). A knitted wearable flexible sensor for monitoring breathing condition. J. Eng. Fibers Fabrics15:1558925020930354. doi: 10.1177/1558925020930354
32
WarnckeM.B"ohmerC.SachseC.FischerS.HäntzscheE.NockeA.et al. (2023). Advancing smart textiles: structural evolution of knitted piezoresistive strain sensors for enabling precise motion capture. Polymers15:3936. doi: 10.3390/polym15193936
33
ZhongW.MingX.JiangH.KeY.DingX.LiM.et al. (2021). Full-textile human motion detection systems integrated by facile weaving with hierarchical core-shell piezoresistive yarns. ACS Appl. Mat. Interf. 13:52901–52911. doi: 10.1021/acsami.1c14777
34
ZhouB.GeisslerD.FaulhaberM.GleissC. E.ZahnE. F.RayL. S. S.et al. (2023). MoCaPose: motion capturing with textile-integrated capacitive sensors in loose-fitting smart garments. Proc. ACM Interact. Mob. Wearable Ubiquitous Technol. 7, 1–40. doi: 10.1145/3580883
Summary
Keywords
e-textiles, joint motion detection, knitted strain sensors, machine learning, sensor characterization, textile integration, wearable sensing
Citation
Schepers A, Zhang Y and Xiao Y (2026) Comparative analysis of knitted resistive strain sensors in joint motion measurements. Front. Comput. Sci. 8:1841675. doi: 10.3389/fcomp.2026.1841675
Received
28 March 2026
Revised
03 June 2026
Accepted
22 July 2026
Published
12 August 2026
Volume
8 - 2026
Edited by
Sizhen Bian, German Research Center for Artificial Intelligence (DFKI), Germany
Reviewed by
Weibin Zhu, Chongqing University, China
Muhammad Yousif, Tianjin Polytechnic University, China
Jose Guillermo Colli Alfaro, Western University, Canada
Updates
Copyright
© 2026 Schepers, Zhang and Xiao.
This is an open-access article distributed under the terms of the Creative Commons Attribution License (CC BY). The use, distribution or reproduction in other forums is permitted, provided the original author(s) and the copyright owner(s) are credited and that the original publication in this journal is cited, in accordance with accepted academic practice. No use, distribution or reproduction is permitted which does not comply with these terms.
*Correspondence: Yu Xiao, yu.xiao@aalto.fi
Disclaimer
All claims expressed in this article are solely those of the authors and do not necessarily represent those of their affiliated organizations, or those of the publisher, the editors and the reviewers. Any product that may be evaluated in this article or claim that may be made by its manufacturer is not guaranteed or endorsed by the publisher.